

 README




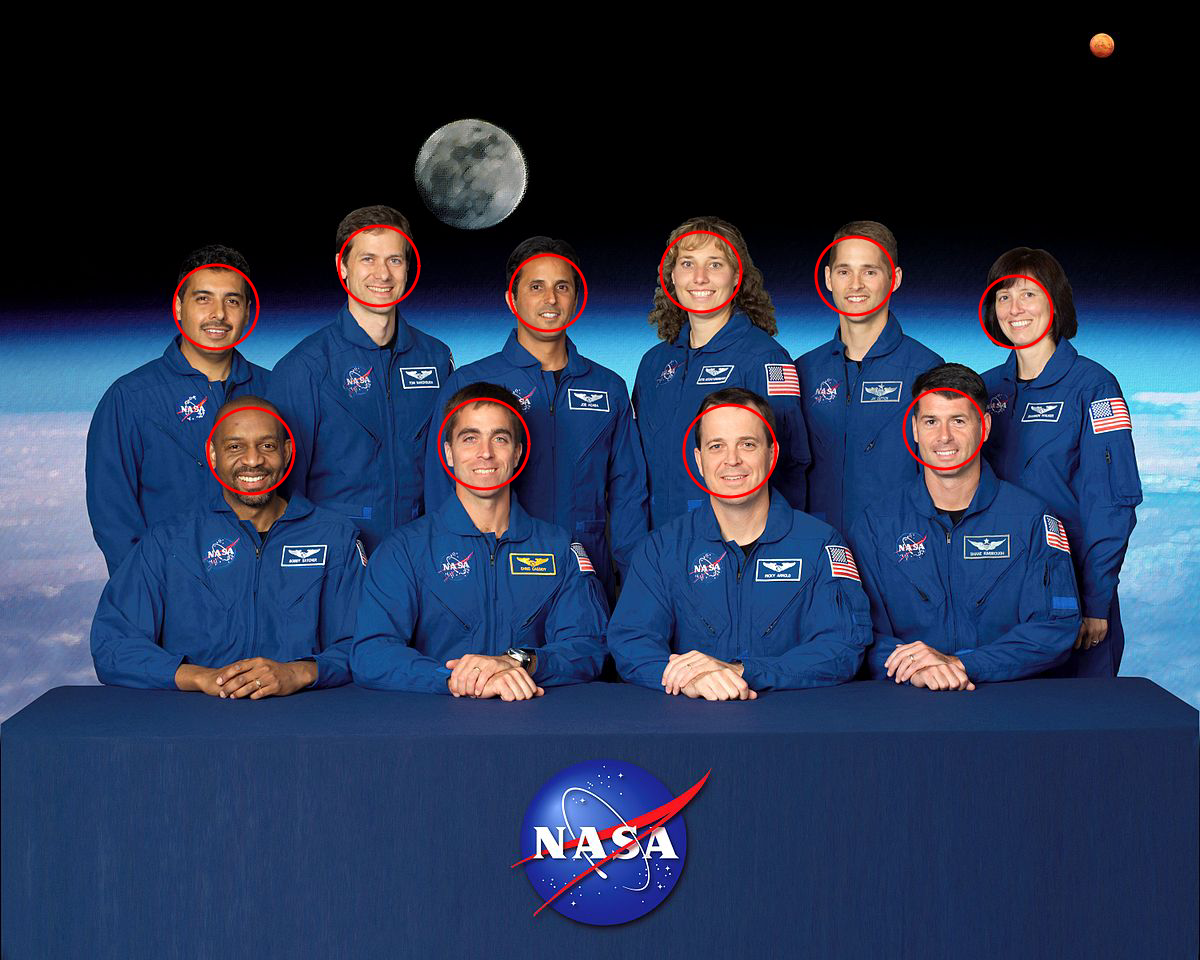
Pigo is a pure Go face detection, pupil/eyes localization and facial landmark points detection library based on the Pixel Intensity Comparison-based Object detection paper.
| Rectangle face marker | Circle face marker |
|---|---|
 |
 |
Motivation
The reason why this library has been developed is because all of the currently existing solutions for face and facial landmark points detections the Go ecosystem are purely bindings, wrappers to other C/C++ libraries like OpenCV or dlib, but calling a C program through cgo introduces unnecessary latencies and produces a significant trade-off in terms of performance. Also, in many cases installing OpenCV on various platforms is cumbersome.
Key features
- Does not require OpenCV or any 3rd party modules to be installed
- High processing speed
- There is no need for image preprocessing prior to detection
- There is no need for the computation of integral images, image pyramid, HOG pyramid or any other similar data structure
- The face detection is based on pixel intensity comparison encoded in the binary file tree structure
- Fast detection of in-plane rotated faces
- The cascade files are directly embedded into the generated binary file
- Pupils/eyes localization
- Facial landmark points detection
- Webassembly support 🎉
Todo
- Object detection and description
The library does not require any additional modules or third party applications to be installed, although you might need to install Python and OpenCV if you wish to try out the provided demos running in real time. Head over to this subtopic for more details.
The library can also detect in plane rotated faces. For this reason a new -angle parameter has been included into the command line utility. The command below will generate the following result (see the table below for all the supported options).
$ pigo -in input.jpg -out output.jpg -angle=0.8 -iou=0.01
| Input file | Output file |
|---|---|
 |
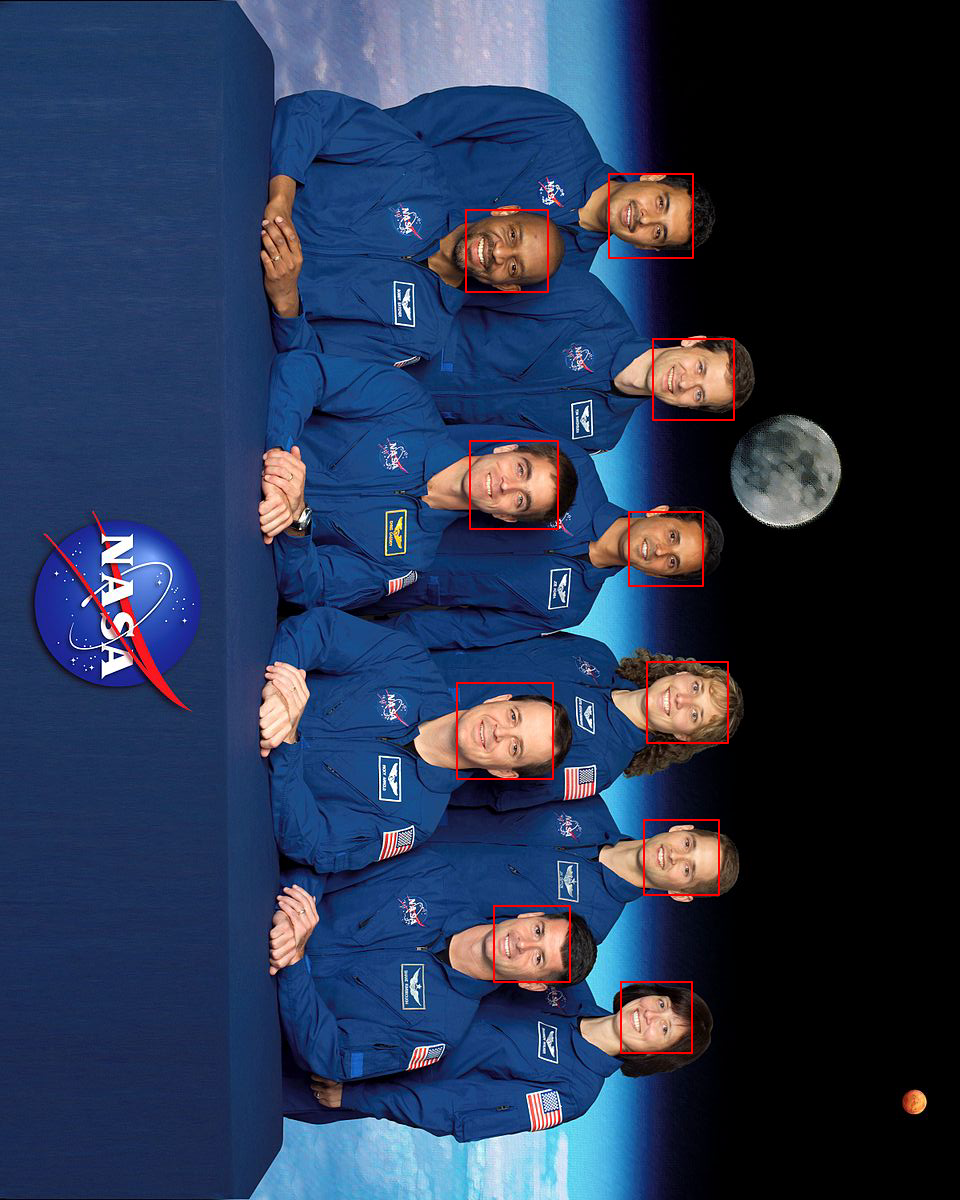 |
Note: In case of in plane rotated faces the angle value should be adapted to the provided image.
Pupils / eyes localization
Starting from v1.2.0 Pigo supports pupils/eyes localization capabilities also. The implementation is based on Eye pupil localization with an ensemble of randomized trees.
Check out this real time demo: https://github.com/esimov/pigo/tree/master/examples/puploc

Facial landmark points detection
v1.3.0 marks a new milestone in the library evolution, Pigo being able to detect facial landmark points. The implementation is based on Fast Localization of Facial Landmark Points.
Check out this real time demo: https://github.com/esimov/pigo/tree/master/examples/facial_landmark

Install
Install Go, set your GOPATH, and make sure $GOPATH/bin is on your PATH.
$ go install github.com/esimov/pigo/cmd/pigo@latest
API
Below is a minimal example of using the face detection API.
First, you need to load and parse the binary classifier, then convert the image to grayscale mode, and finally run the cascade function which returns a slice containing the row, column, scale and the detection score.
src, err := pigo.GetImage("/path/to/image")
if err != nil {
	log.Fatalf("Cannot open the image file: %v", err)
}

pixels := pigo.RgbToGrayscale(src)
cols, rows := src.Bounds().Max.X, src.Bounds().Max.Y

cParams := pigo.CascadeParams{
	MinSize:     20,
	MaxSize:     1000,
	ShiftFactor: 0.1,
	ScaleFactor: 1.1,

	ImageParams: pigo.ImageParams{
		Pixels: pixels,
		Rows:   rows,
		Cols:   cols,
		Dim:    cols,
	},
}

p := pigo.NewPigo()
// Unpack the binary file. This will return the number of cascade trees,
// the tree depth, the threshold and the prediction from tree's leaf nodes.
classifier := p.Unpack()

angle := 0.0 // cascade rotation angle. 0.0 is 0 radians and 1.0 is 2*pi radians

// Run the classifier over the obtained leaf nodes and return the detection results.
// The result contains quadruplets representing the row, column, scale and detection score.
dets := classifier.RunCascade(cParams, angle)

// Calculate the intersection over union (IoU) of two clusters.
dets = classifier.ClusterDetections(dets, 0.2)
Usage
A command line utility is bundled into the library.
$ pigo -in input.jpg -out out.jpg
Supported flags:
$ pigo --help

┌─┐┬┌─┐┌─┐
├─┘││ ┬│ │
┴  ┴└─┘└─┘

Go (Golang) Face detection library.
    Version: 1.5.0

  -angle float
        0.0 is 0 radians and 1.0 is 2*pi radians
  -flploc
        Activate facial landmark points localization
  -in string
        Source image (default "-")
  -iou float
        Intersection over union (IoU) threshold (default 0.15)
  -json string
        Output the detection points into a json file
  -mark
        Mark detected eyes (default true)
  -marker string
        Detection marker: rect|circle|ellipse (default "rect")
  -max int
        Maximum size of face (default 1000)
  -min int
        Minimum size of face (default 20)
  -out string
        Destination image (default "-")
  -puploc
        Activate pupils/eyes localization
  -scale float
        Scale detection window by percentage (default 1.15)
  -shift float
        Shift detection window by percentage (default 0.15)
Notice: The library automatically embeds the cascade files required for pupil/eyes localization and facial landmark points detection.
CLI command examples
You can also use the stdin and stdout pipe commands:
$ cat input/source.jpg | pigo > -in - -out - >out.jpg
in and out default to - so you can also use:
$ cat input/source.jpg | pigo >out.jpg
$ pigo -out out.jpg < input/source.jpg
Using the empty string as value for the -out flag will skip the image generation part. This, combined with the -json flag will encode the detection results into the specified json file. You can also use the pipe - value combined with the -json flag to output the detection coordinates to the standard (stdout) output.
Real time face detection (running as a shared object)
If you wish to test the library's real time face detection capabilities as a desktop application, the examples folder contains a few demos written in Python.
The obvious question is why Python? Because the Go ecosystem is (still) missing a cross platform and system independent library for accessing the webcam.
We opted for Python just because it's very simple to write a simple script to access the webcam.
How does it works?
From the Python script we access the webcam, converts the pixel data to a byte array and through cgo we transfer the results as a shared object to the Go program where the core face detection is happening. But as you can imagine this operation is not cost effective, resulting in lower frame rates and higher latency than the library is capable of.
WASM (Webassembly) support 🎉
Starting from version v1.4.0 the library has been ported to WASM. This proves the library's real time face detection capabilities, constantly producing ~60 FPS.
WASM demo
To run the wasm demo select the wasm folder and type make. This will open a new tab in the web browser and run the face detector real time.
For more details check the subpage description: https://github.com/esimov/pigo/tree/master/wasm.
For more awesome WASM demos using the Pigo library check this repo: https://github.com/esimov/pigo-wasm-demos.
Releases
In case you do not have installed or do not wish to install Go, you can obtain the binary file from the releases folder.
The library can be accessed as a snapcraft function too.
Benchmark results
Below are the benchmark results obtained running Pigo against GoCV using the same conditions.
    BenchmarkGoCV-4   	       3	 414122553 ns/op	     704 B/op	       1 allocs/op
    BenchmarkPIGO-4   	      10	 173664832 ns/op	       0 B/op	       0 allocs/op
    PASS
    ok  	github.com/esimov/gocv-test	4.530s
The code used for the above test can be found under the following link: https://github.com/esimov/pigo-gocv-benchmark
Author
- Endre Simo (@simo_endre)
License
Copyright © 2019 Endre Simo
This software is distributed under the MIT license. See the LICENSE file for the full license text.
 Directories

| Path | Synopsis |
|---|---|
|
cmd
|
|
|
pigo
command
|
|
|
examples
|
|
|
blinkdet
command
|
|
|
facedet
command
|
|
|
facial_landmark
command
|
|
|
masquerade
command
|
|
|
puploc
command
|
|
|
talk_detector
command
|
|
|
web
command
|
|
|
Package pigo is a lightweight pure Go face detection, pupil/eyes localization and facial landmark points detection library based on Pixel Intensity Comparison-based Object detection paper (https://arxiv.org/pdf/1305.4537.pdf).
|
Package pigo is a lightweight pure Go face detection, pupil/eyes localization and facial landmark points detection library based on Pixel Intensity Comparison-based Object detection paper (https://arxiv.org/pdf/1305.4537.pdf). |
|
http
command
|